2026-11-16
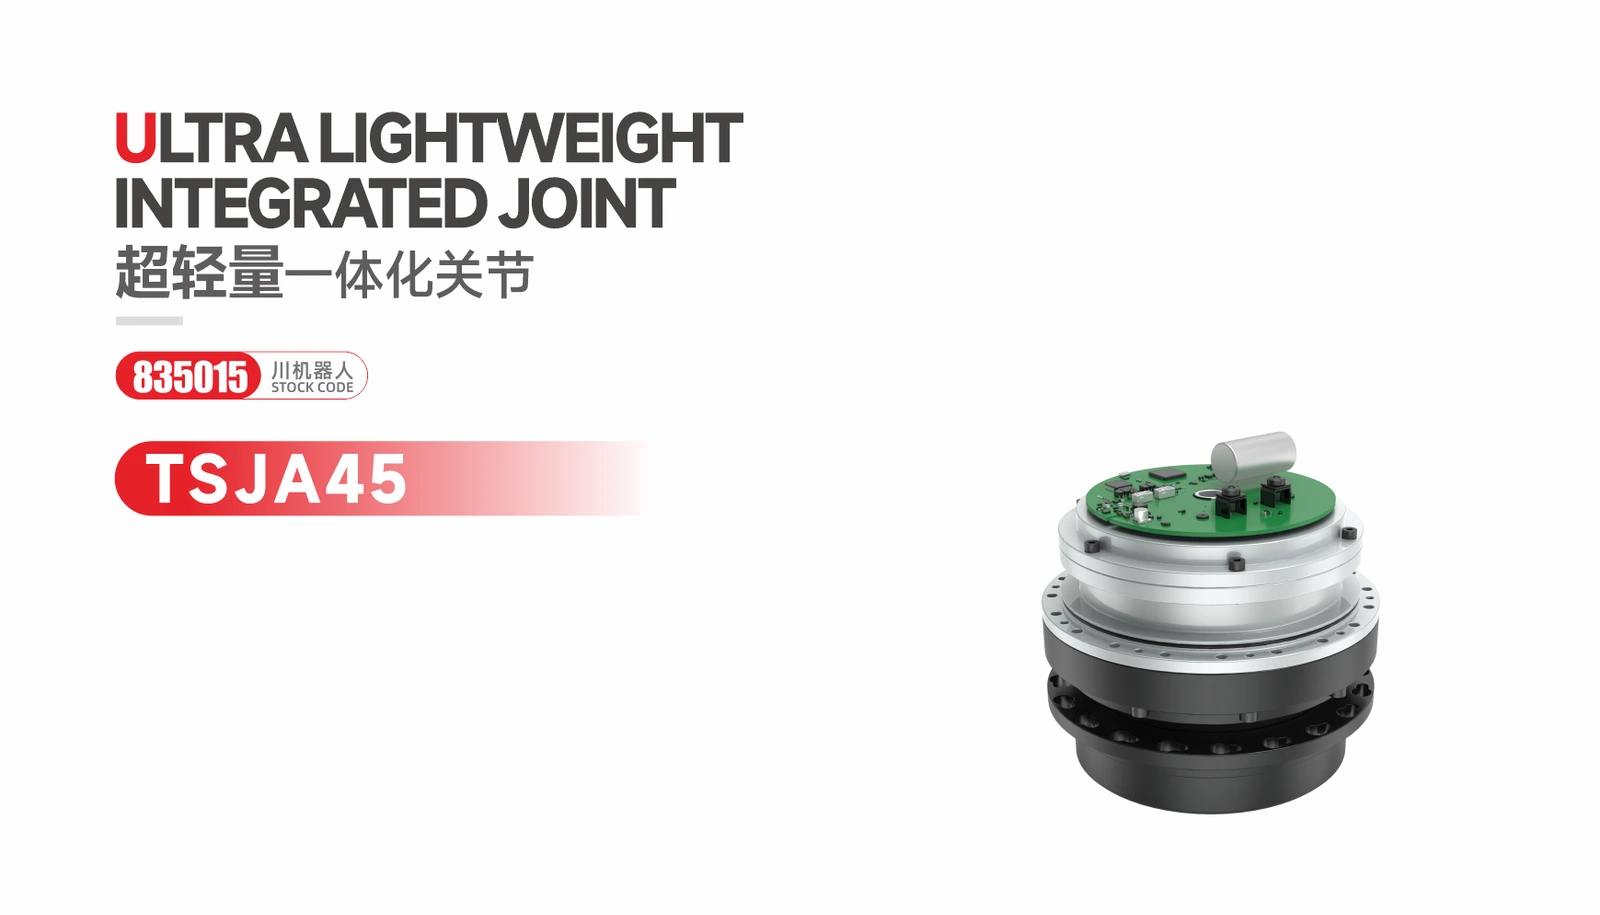
TLIBOT TSJA45 Integrated Joint Module
High-torque integrated rotary joint module family with 48 V supply, 19-bit dual encoders, electromagnetic braking and five ratio-dependent torque and speed configurations.
2026-11-16
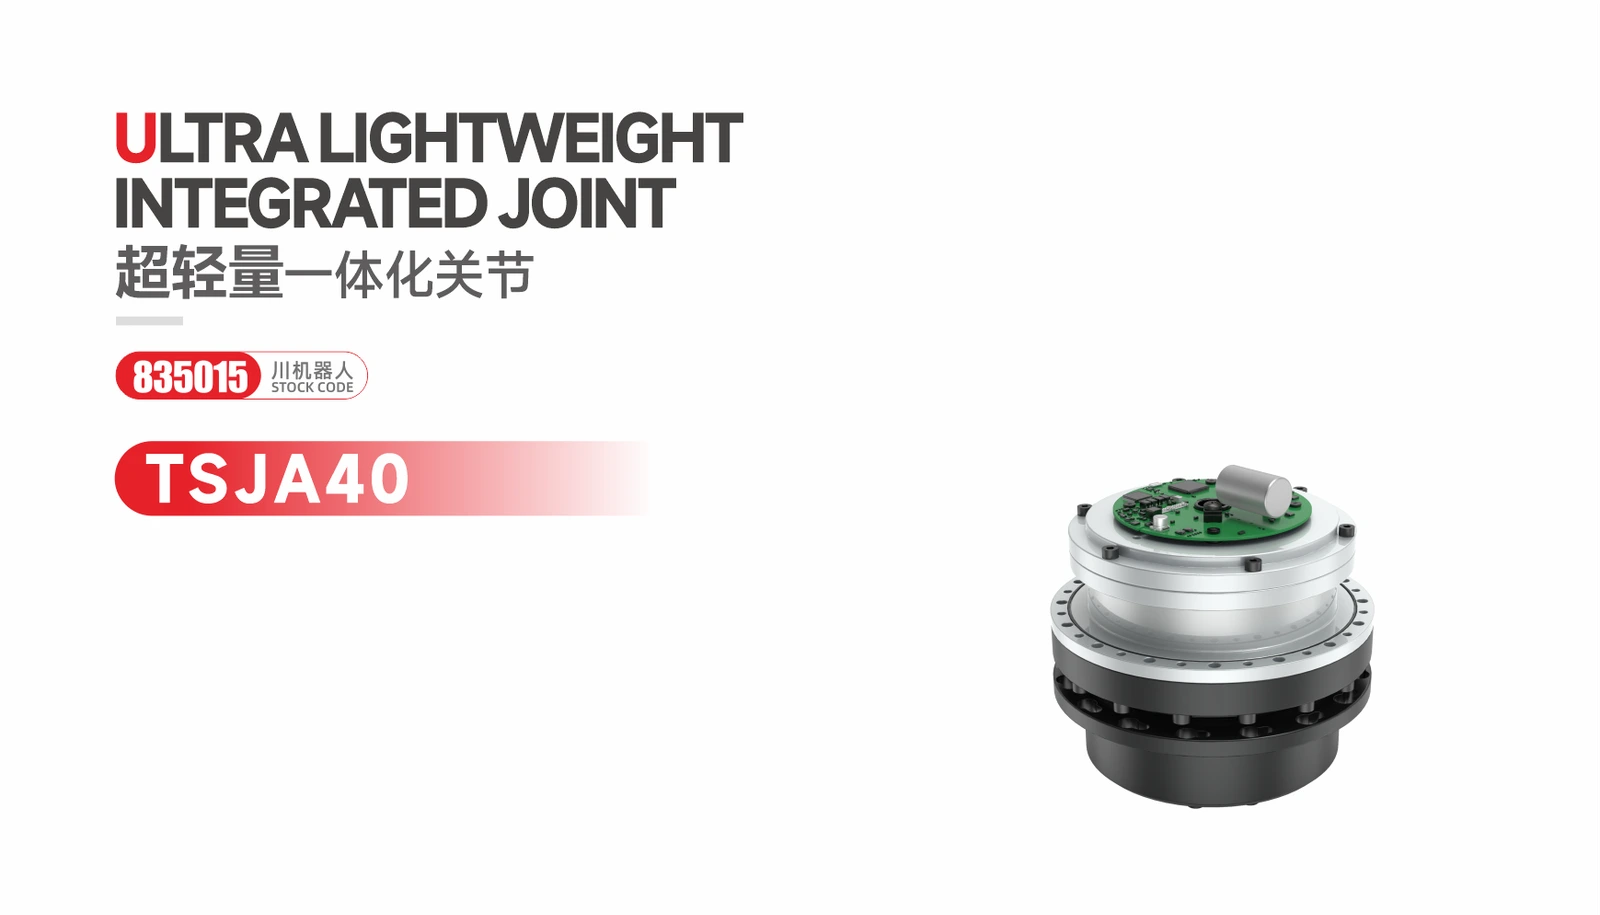
High-torque integrated rotary joint module family with 48 V supply, 19-bit dual encoders, electromagnetic braking and five ratio-dependent torque and speed configurations.
2026-11-16
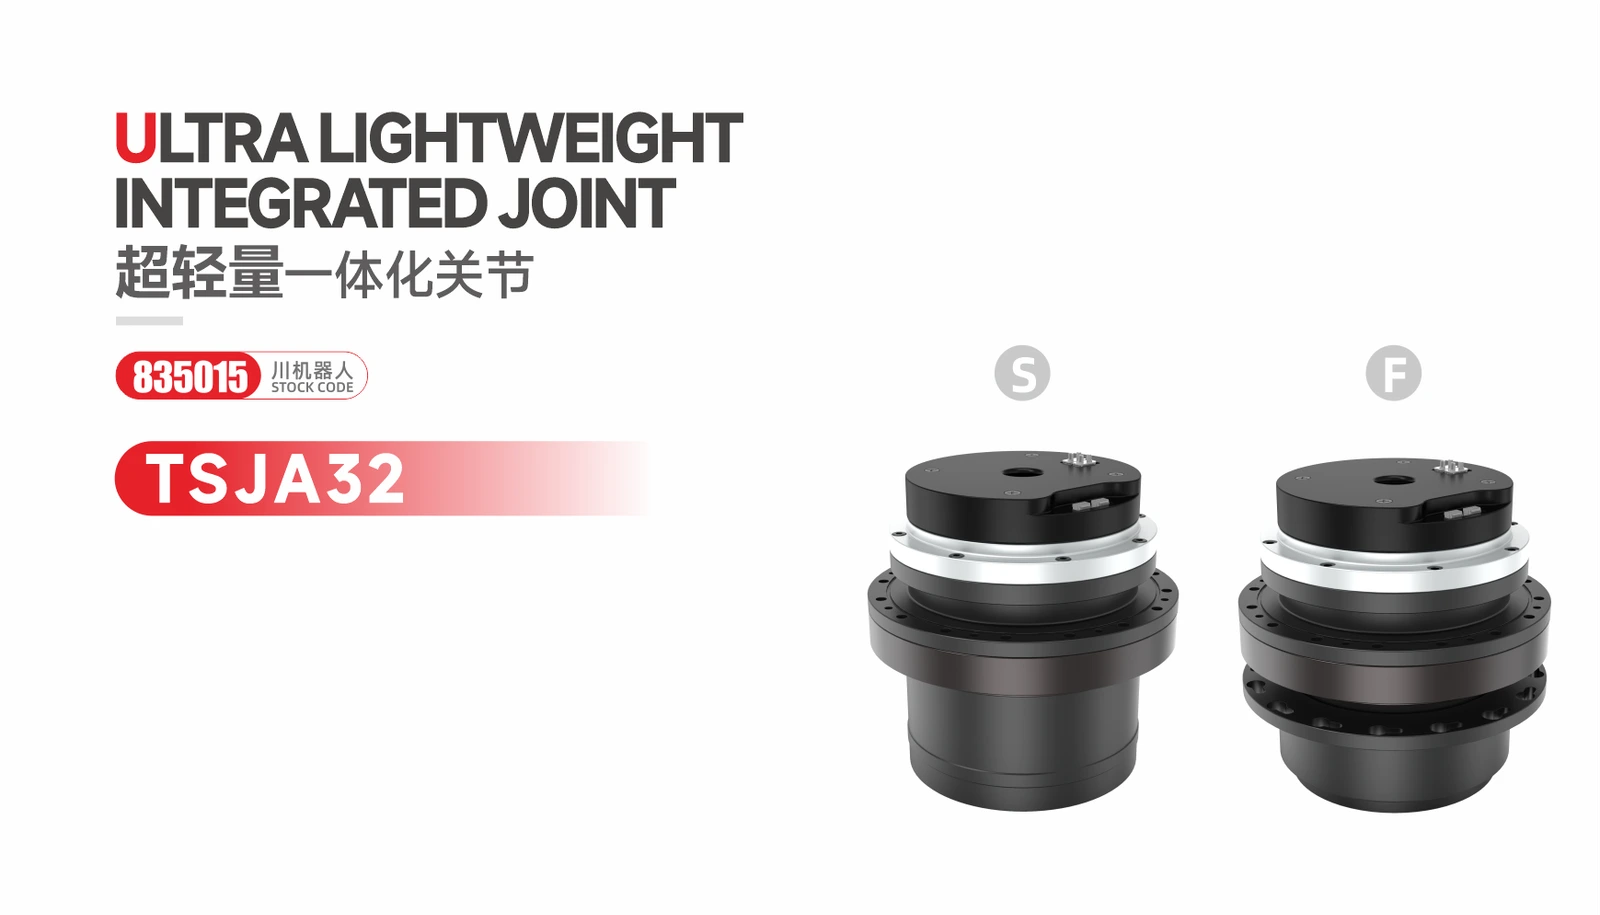
High-torque integrated rotary joint module family with 48 V supply, 19-bit dual encoders, electromagnetic braking and five ratio-dependent torque and speed configurations.
2026-11-16
High-torque integrated rotary joint module family with 48 V supply, 19-bit dual encoders, electromagnetic braking and five ratio-dependent torque and speed configurations.
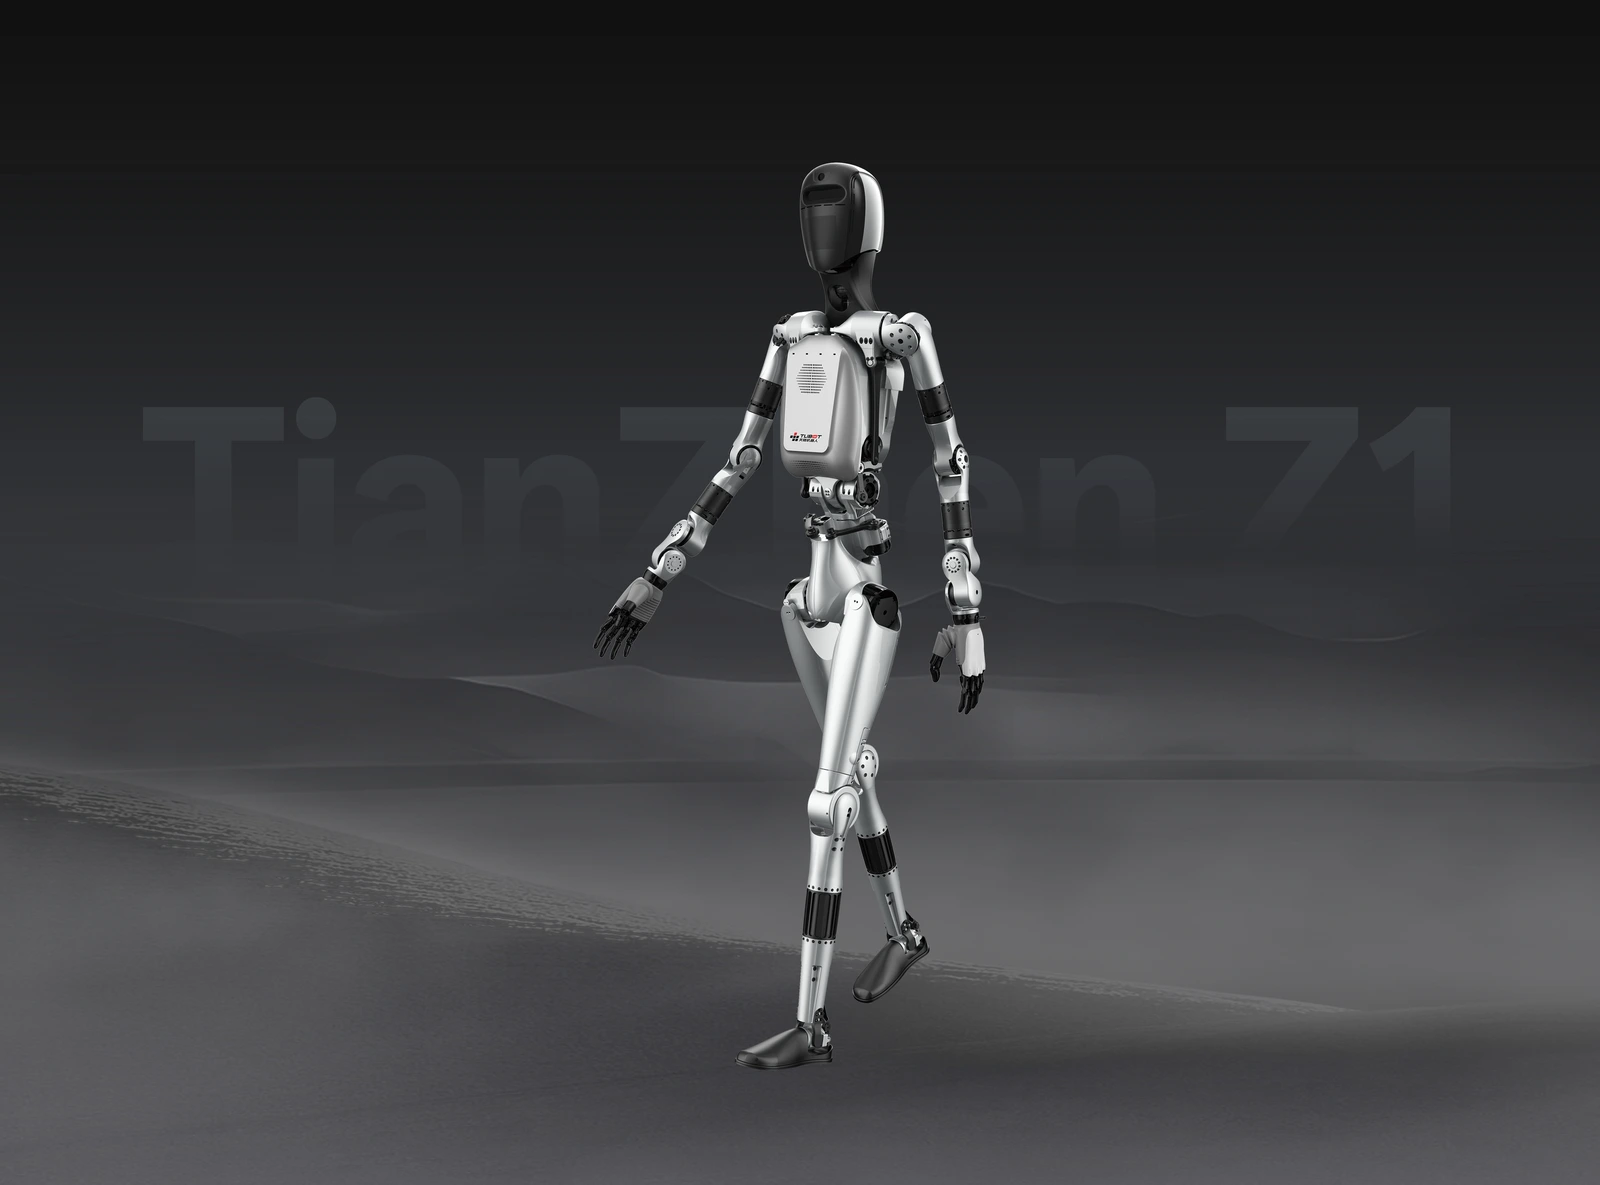
2026-11-16
167 cm humanoid robot with up to 40 degrees of freedom, 3–8 kg arm payload, 2 m/s maximum travel speed, more than two hours of battery life and simulation-model support.
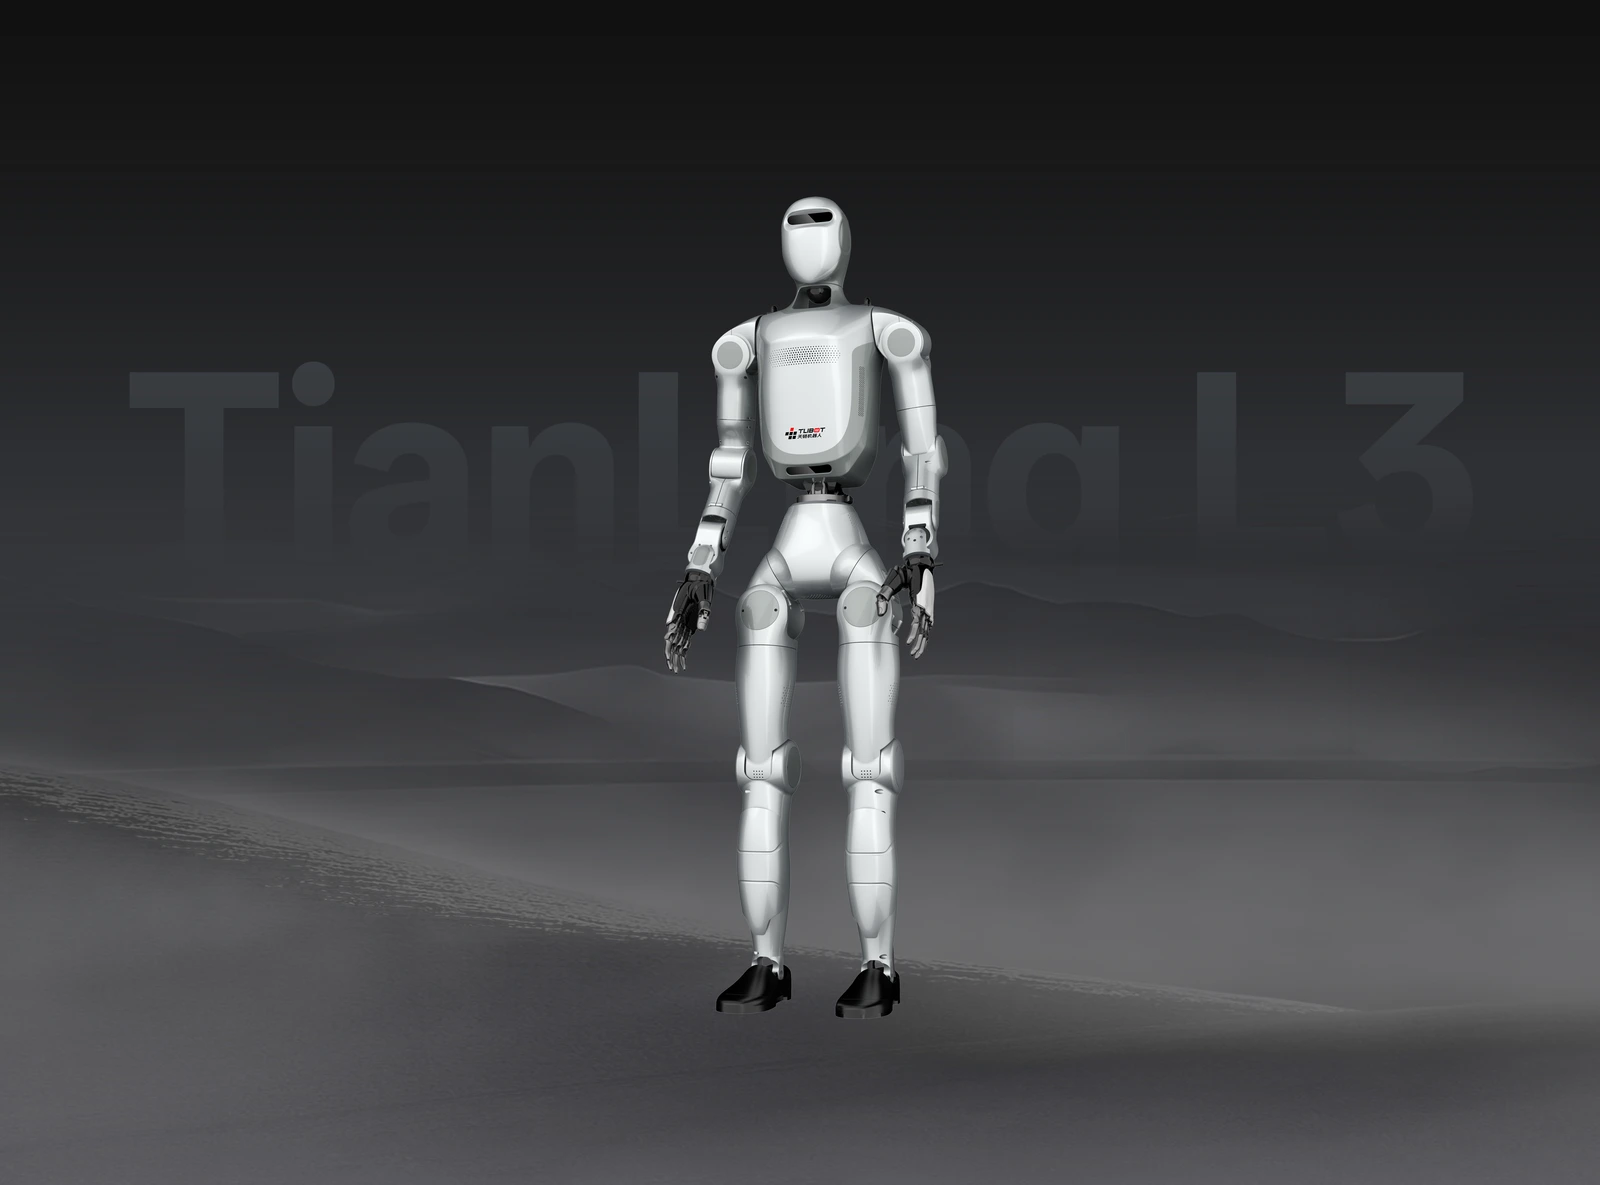
2026-11-16
138 cm humanoid robot with up to 30 degrees of freedom, 4 kg arm payload, 2 m/s maximum travel speed, quick-release 612 Wh battery and simulation-model support.
2026-11-16
Full-size humanoid robot with 71 degrees of freedom, approximately 43 kg battery-inclusive weight, 10 km/h maximum walking speed and up to 145 kg deep-squat load capacity.
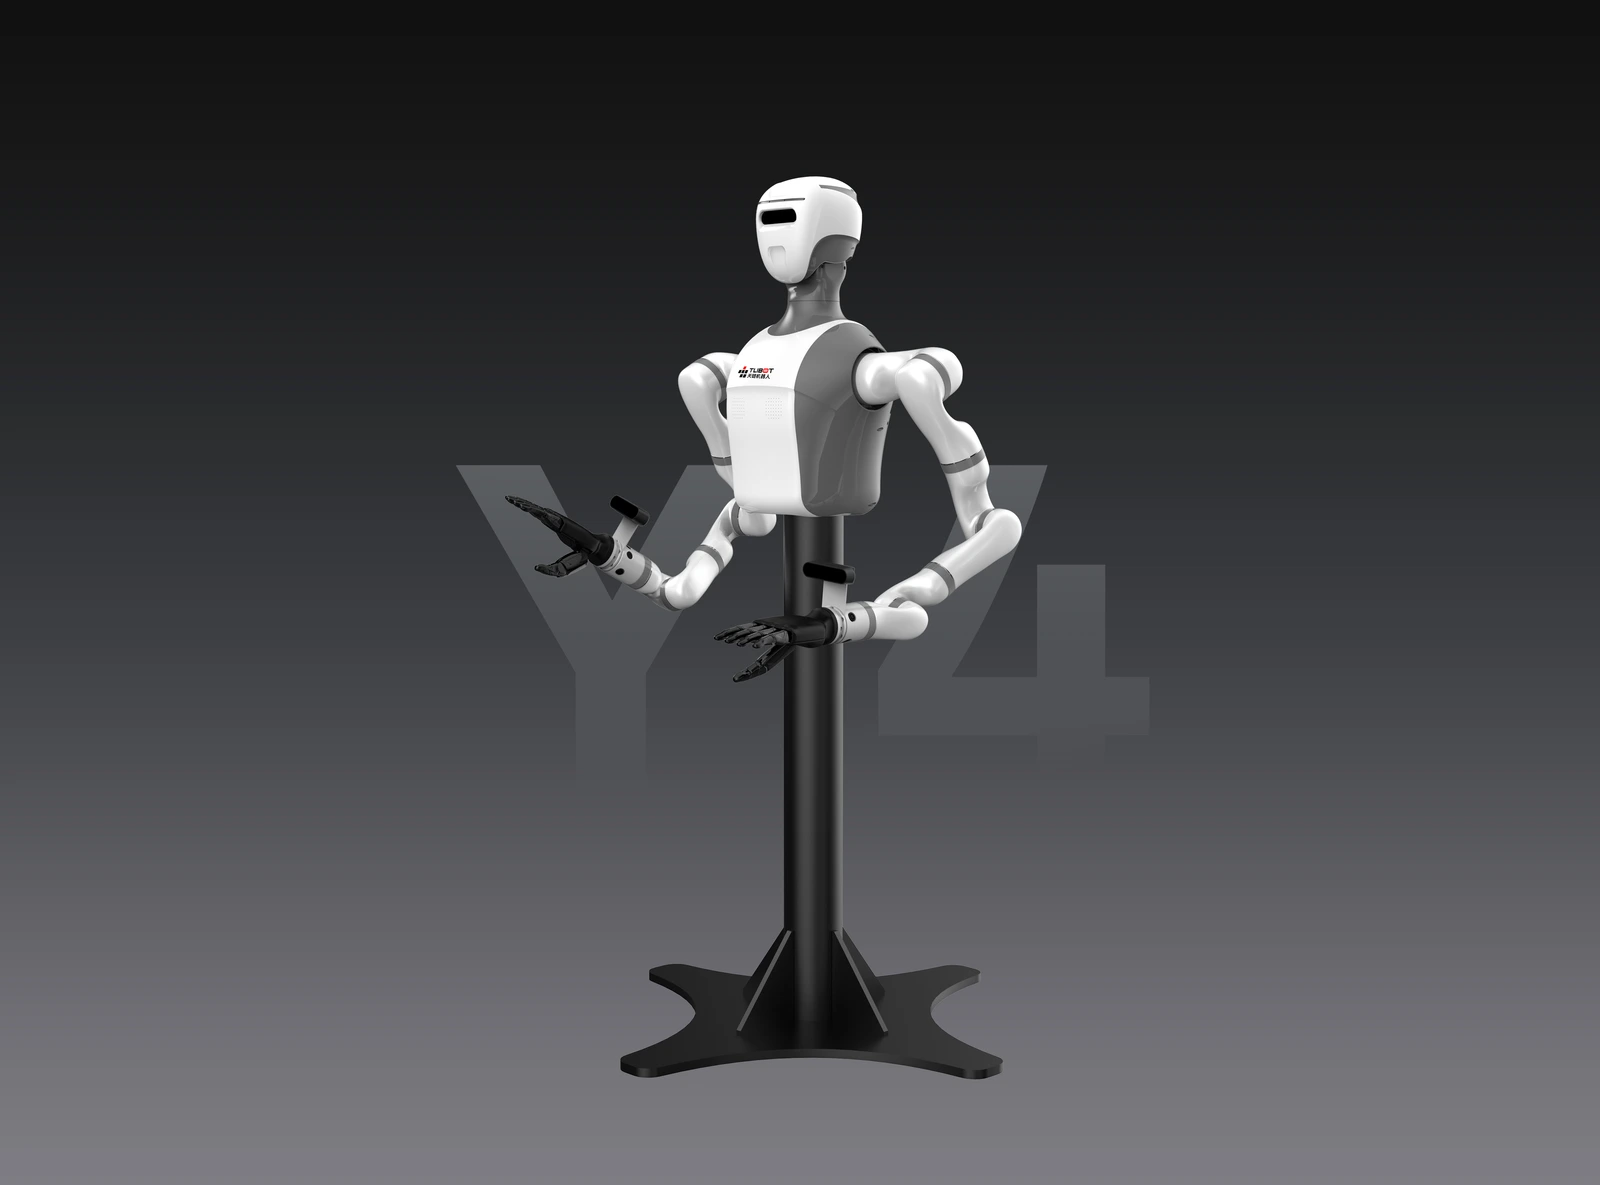
2026-11-16
Fixed pedestal dual-arm composite robot with 5 kg rated load per arm, 1100 mm working height, Ethernet connectivity and ROS2/API secondary-development support.
2026-11-16
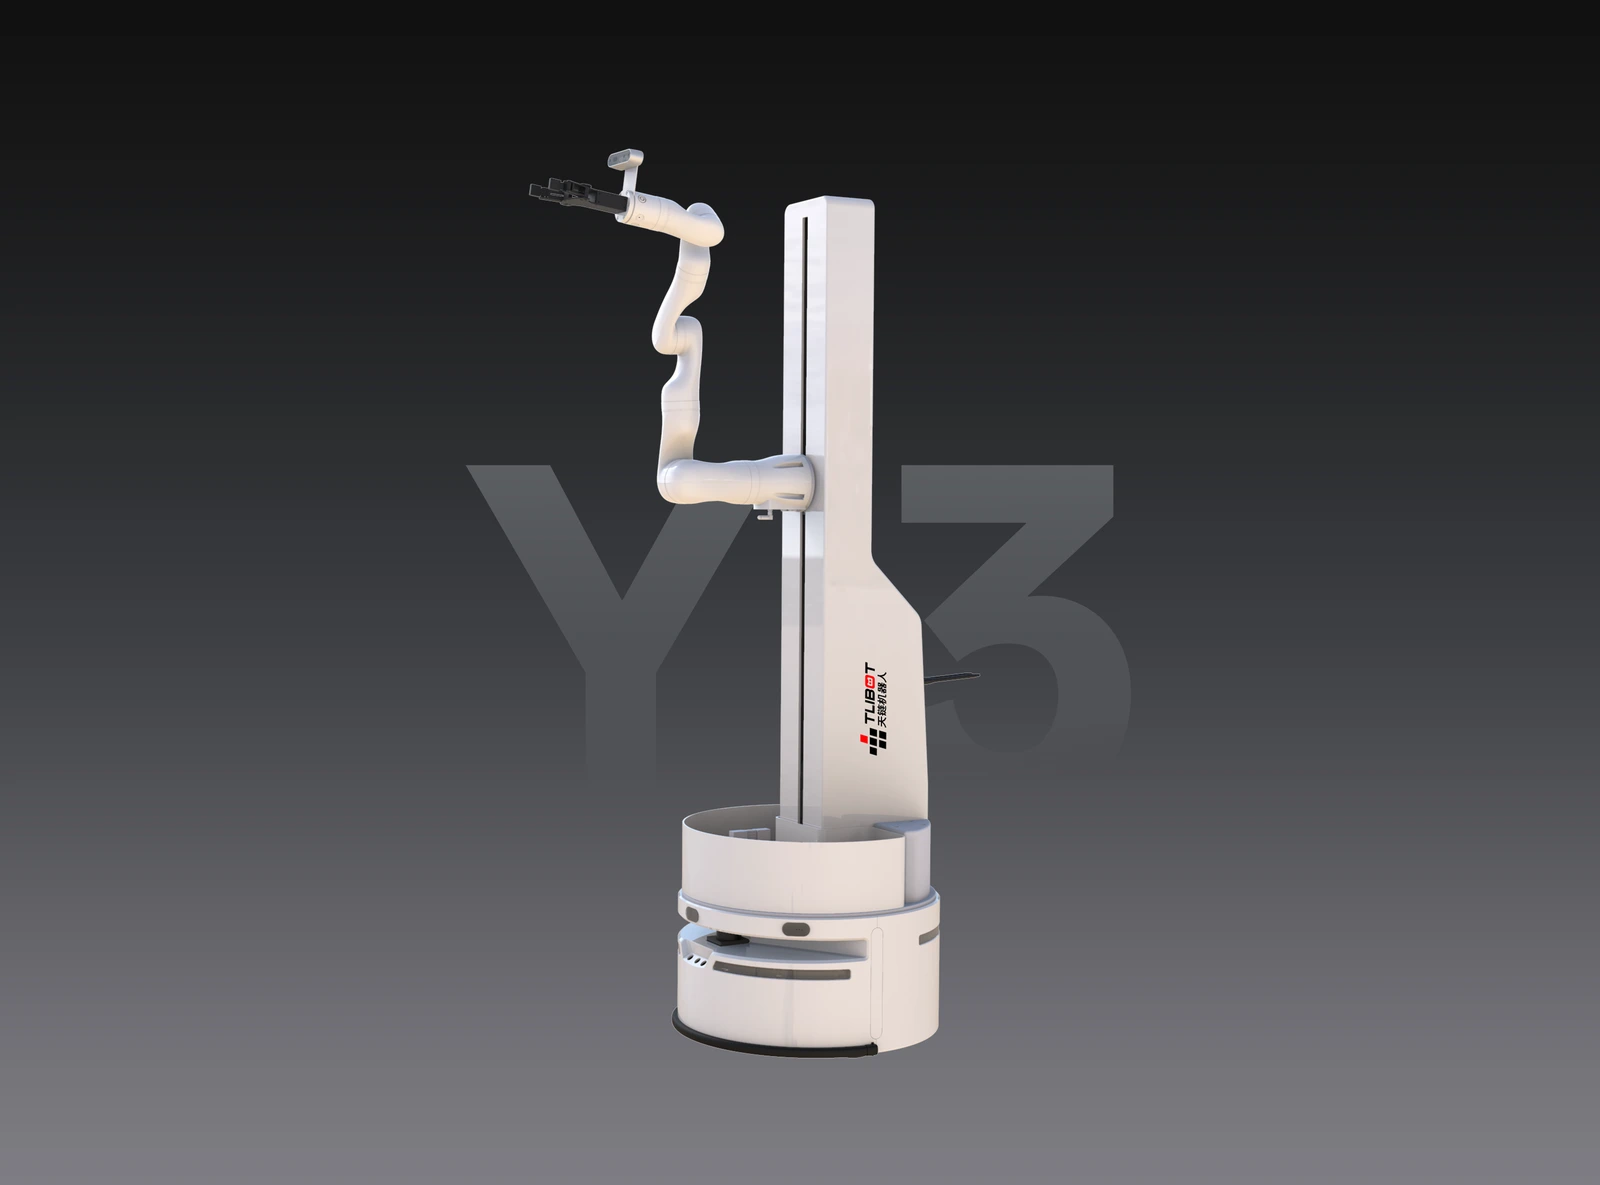
Wheeled single-arm lifting composite robot with 5 kg rated arm payload, 900 mm lifting stroke, LiDAR autonomous navigation and ROS2/API secondary-development support.
2026-11-16
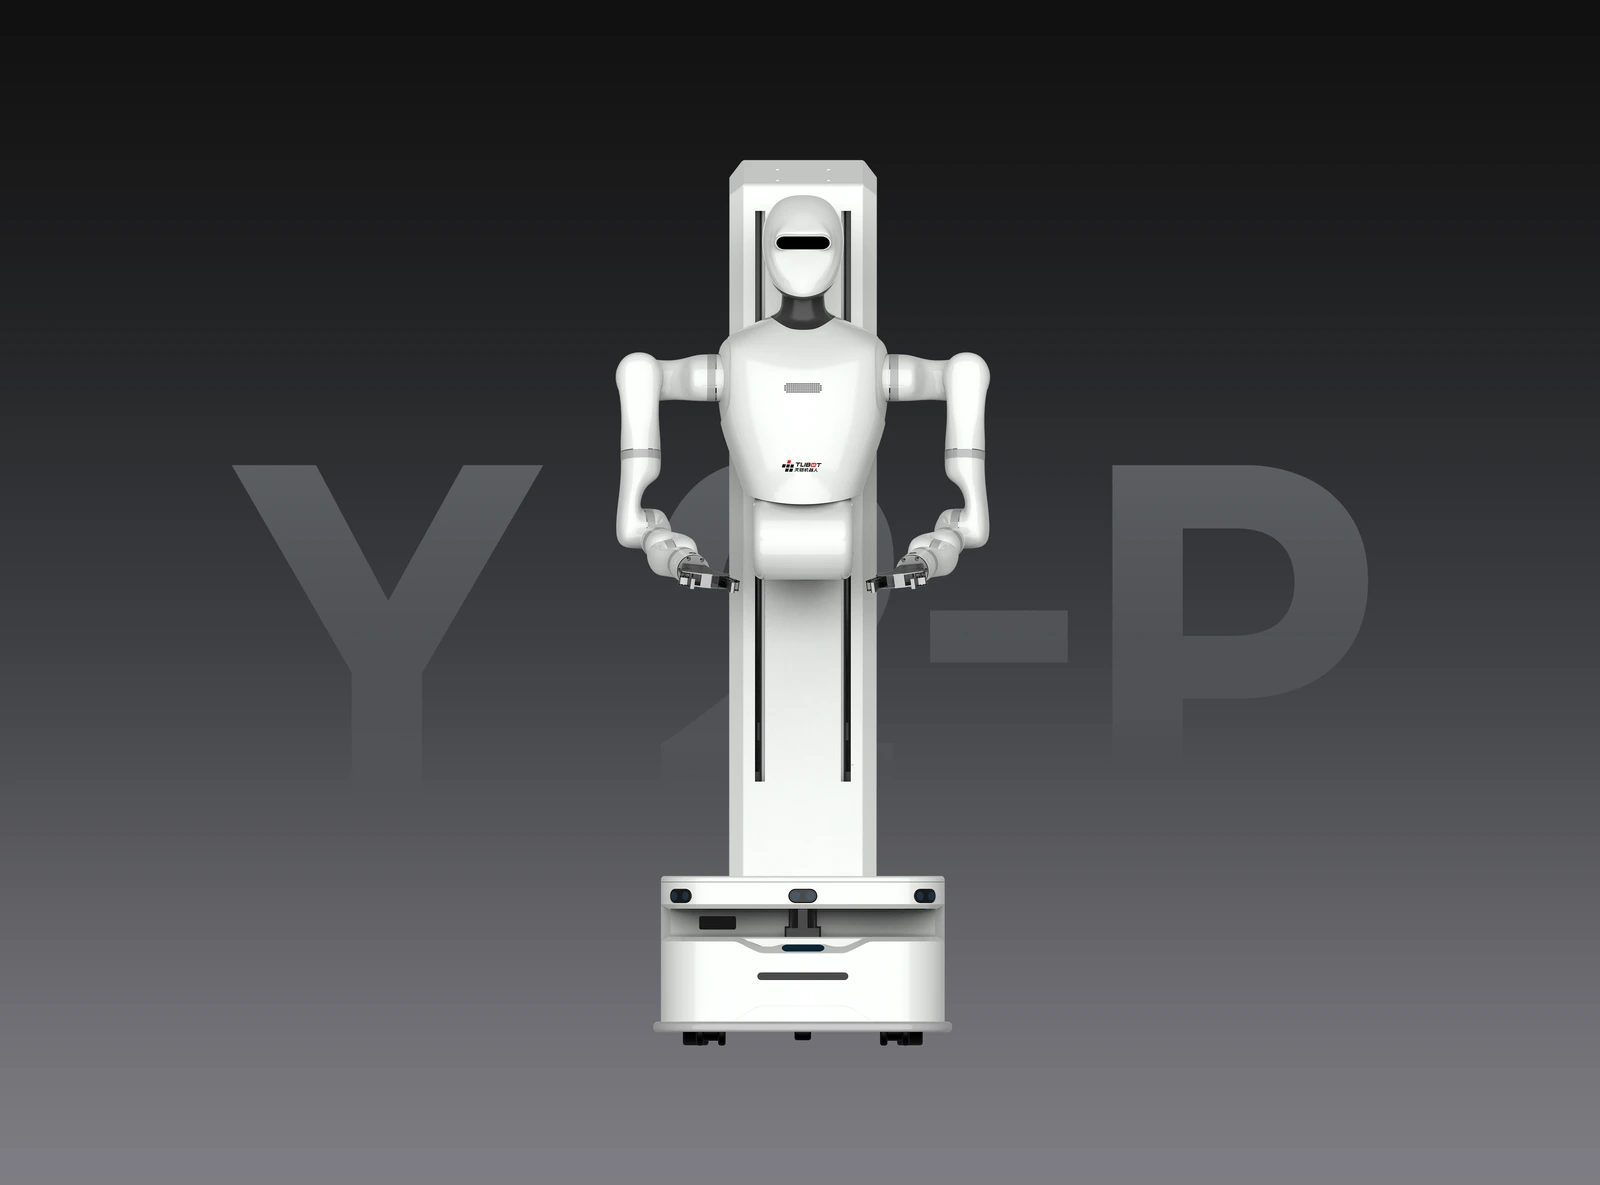
Wheeled dual-arm elevation composite robot with 5 kg rated load per arm, 700 mm lifting stroke, LiDAR autonomous navigation and eight-hour rated working time.
2026-11-16
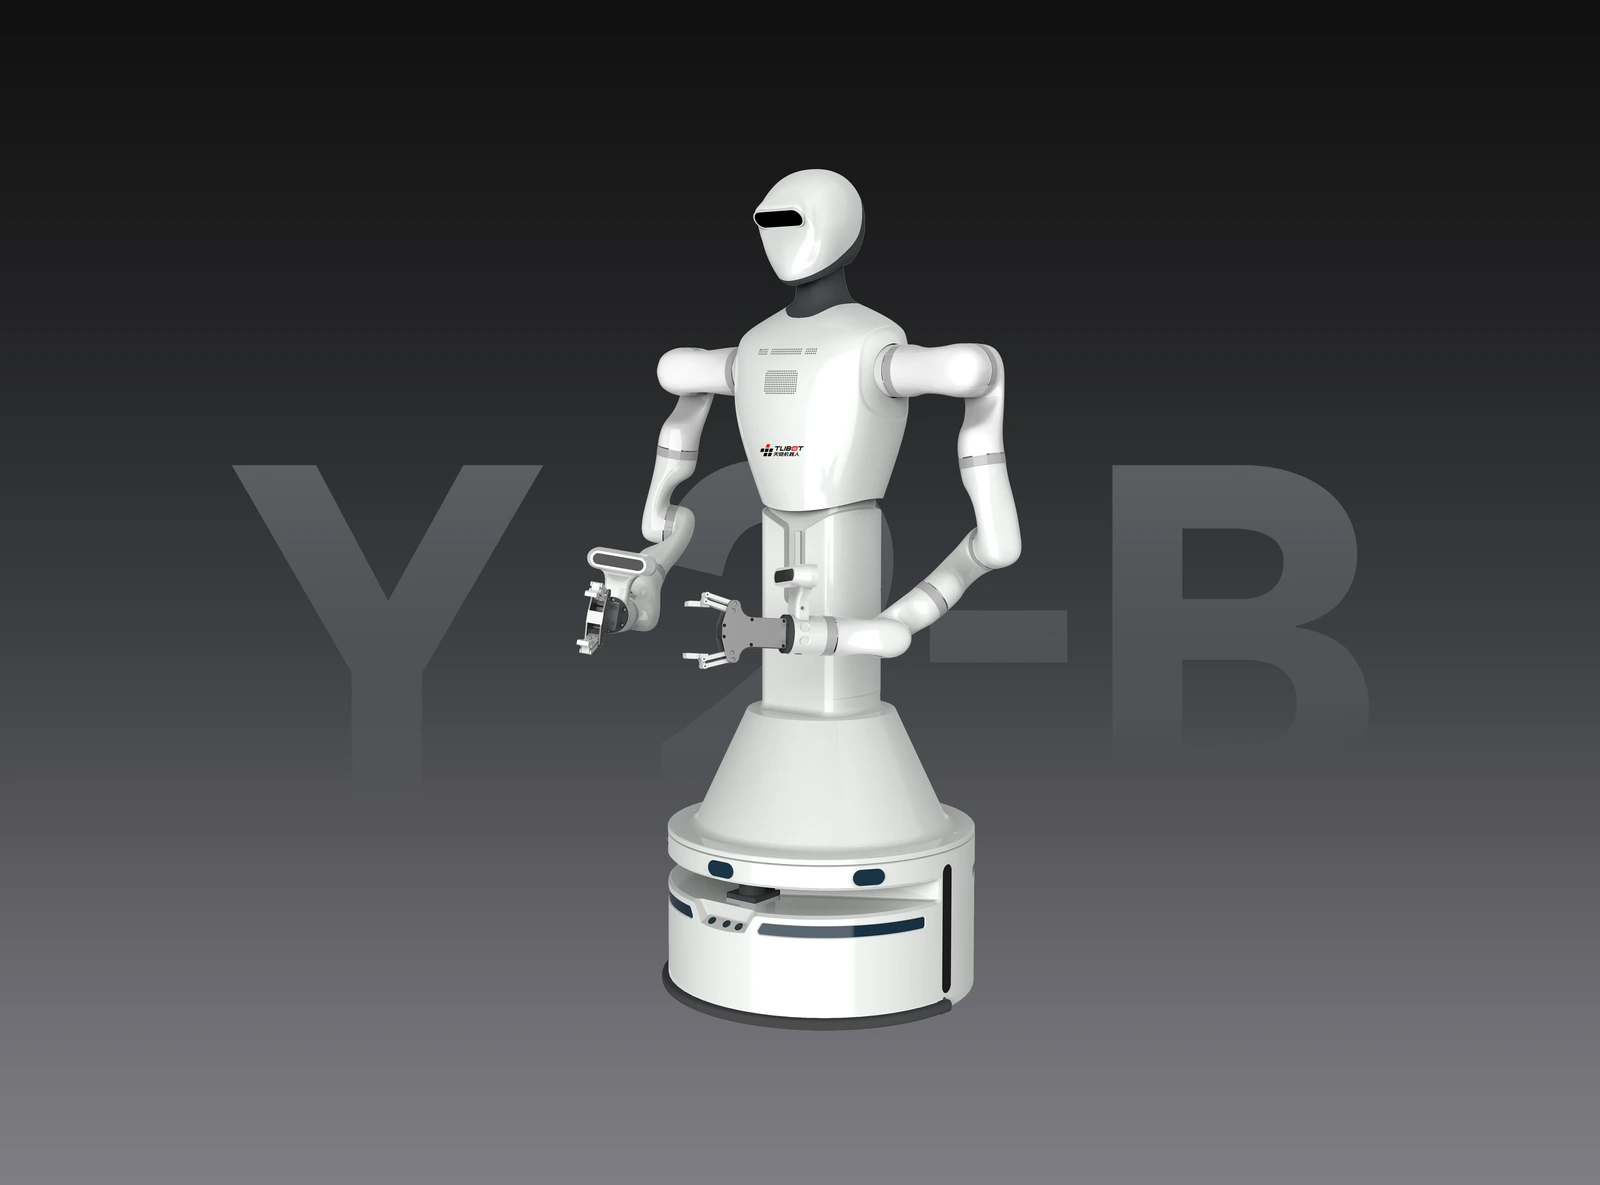
Wheeled dual-arm pitch composite robot with 5 kg rated load per arm, 700 mm lifting stroke, LiDAR autonomous navigation, zero-radius turning and ROS2/API secondary-development support.
2026-11-16
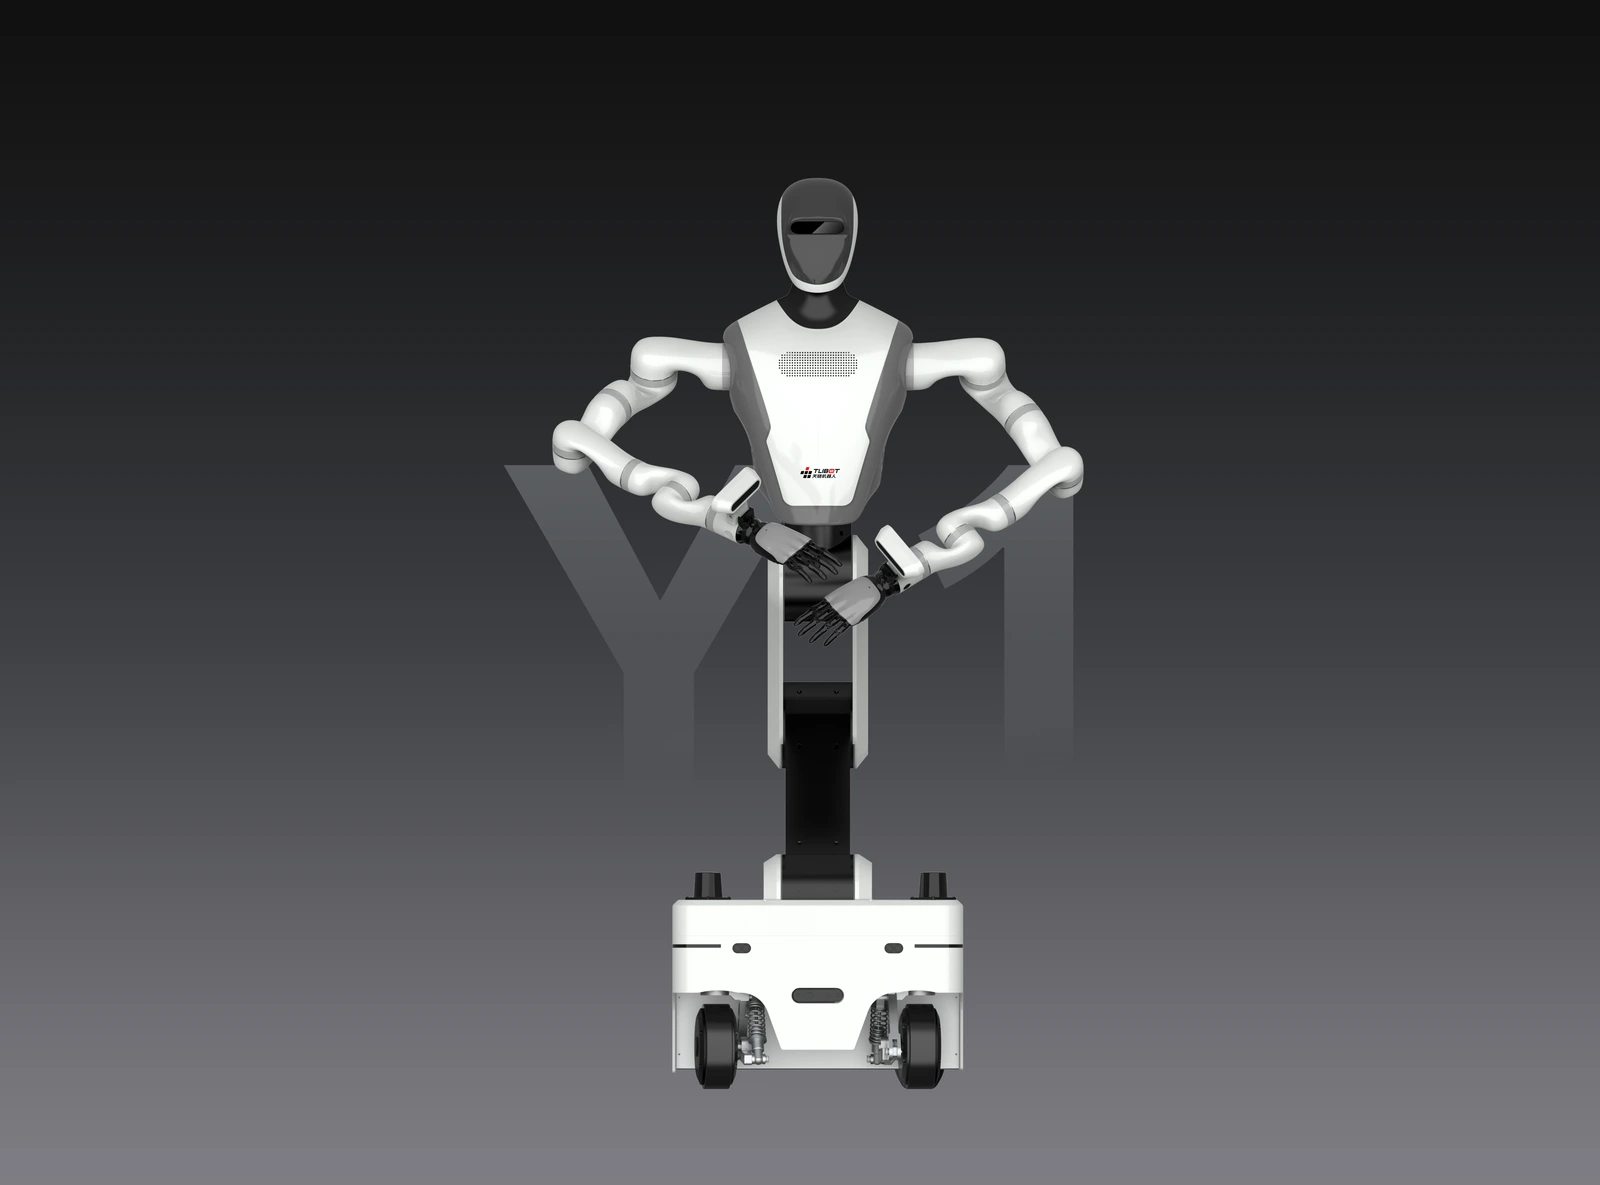
Wheeled folding and lifting composite robot with two 5 kg-payload arms, 500 mm lifting stroke, LiDAR autonomous navigation, zero-radius turning and ROS2/API secondary-development support.
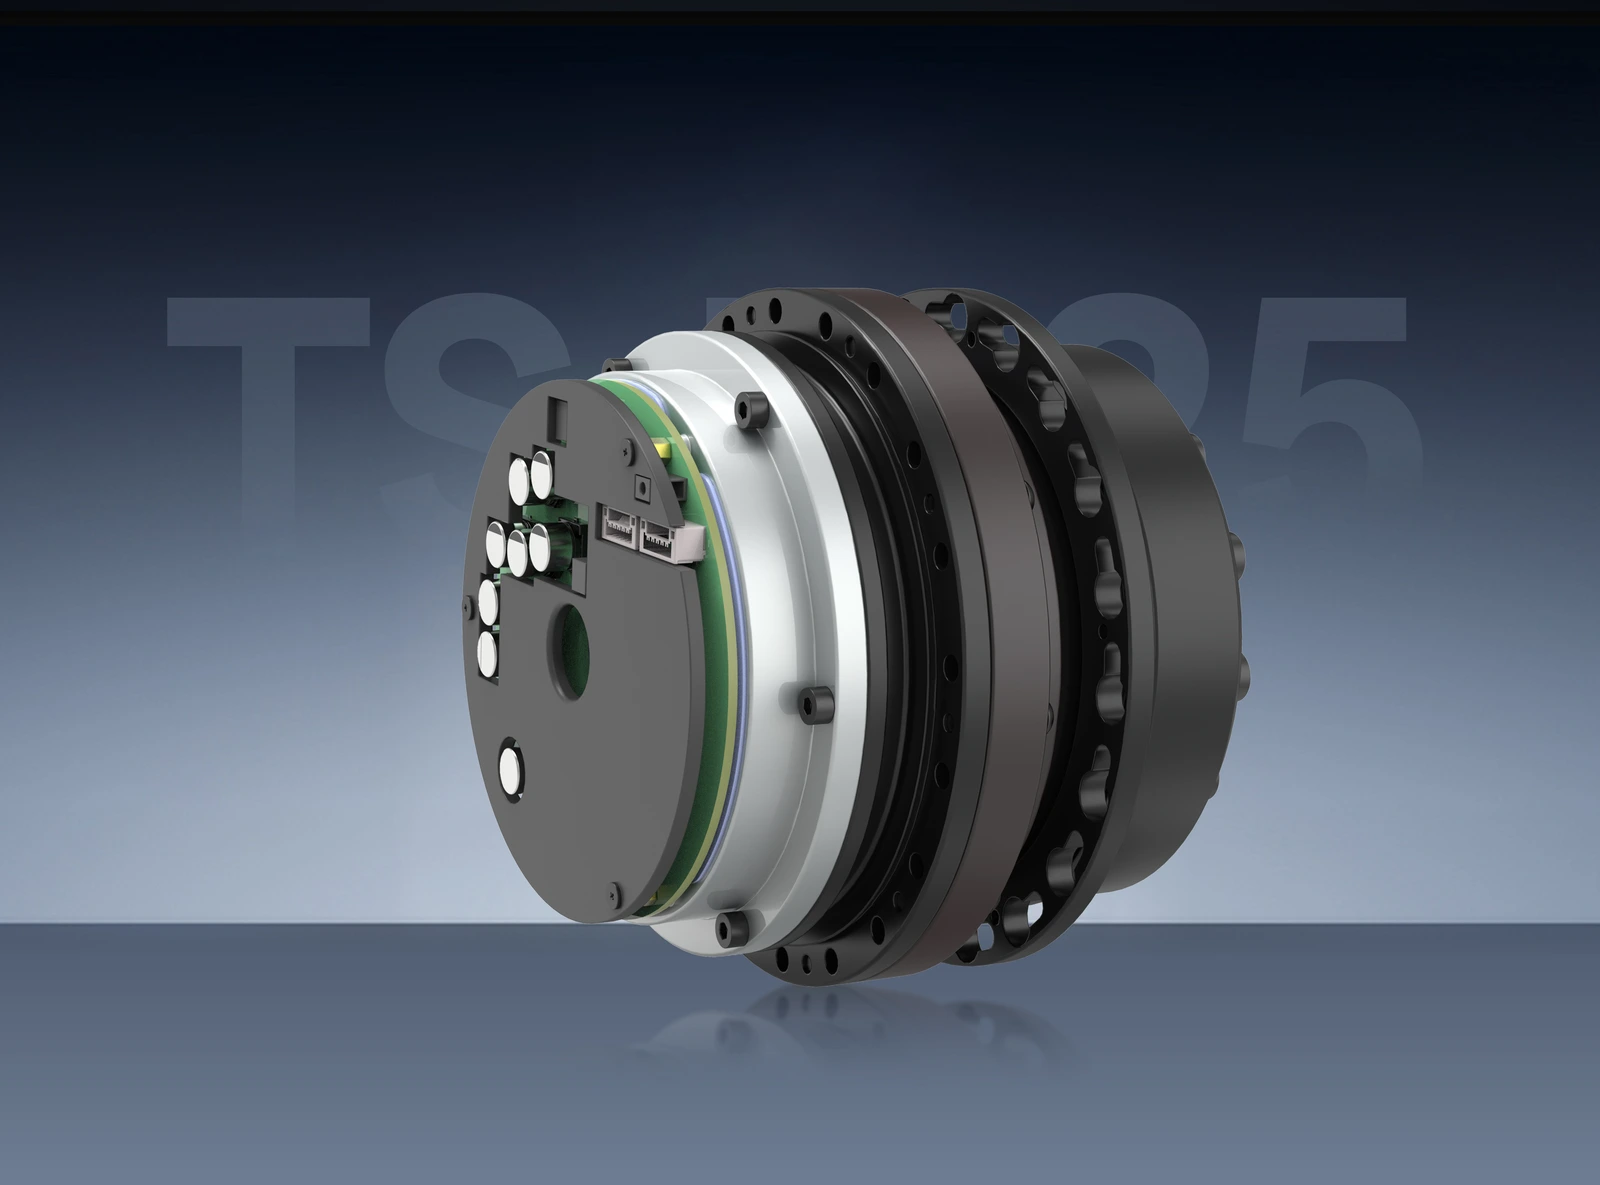
2026-11-16
Integrated rotary joint module series with 48 V supply, EtherCAT communication, 19-bit high- and low-speed encoders, electromagnetic braking and ratio-dependent torque and speed configurations.
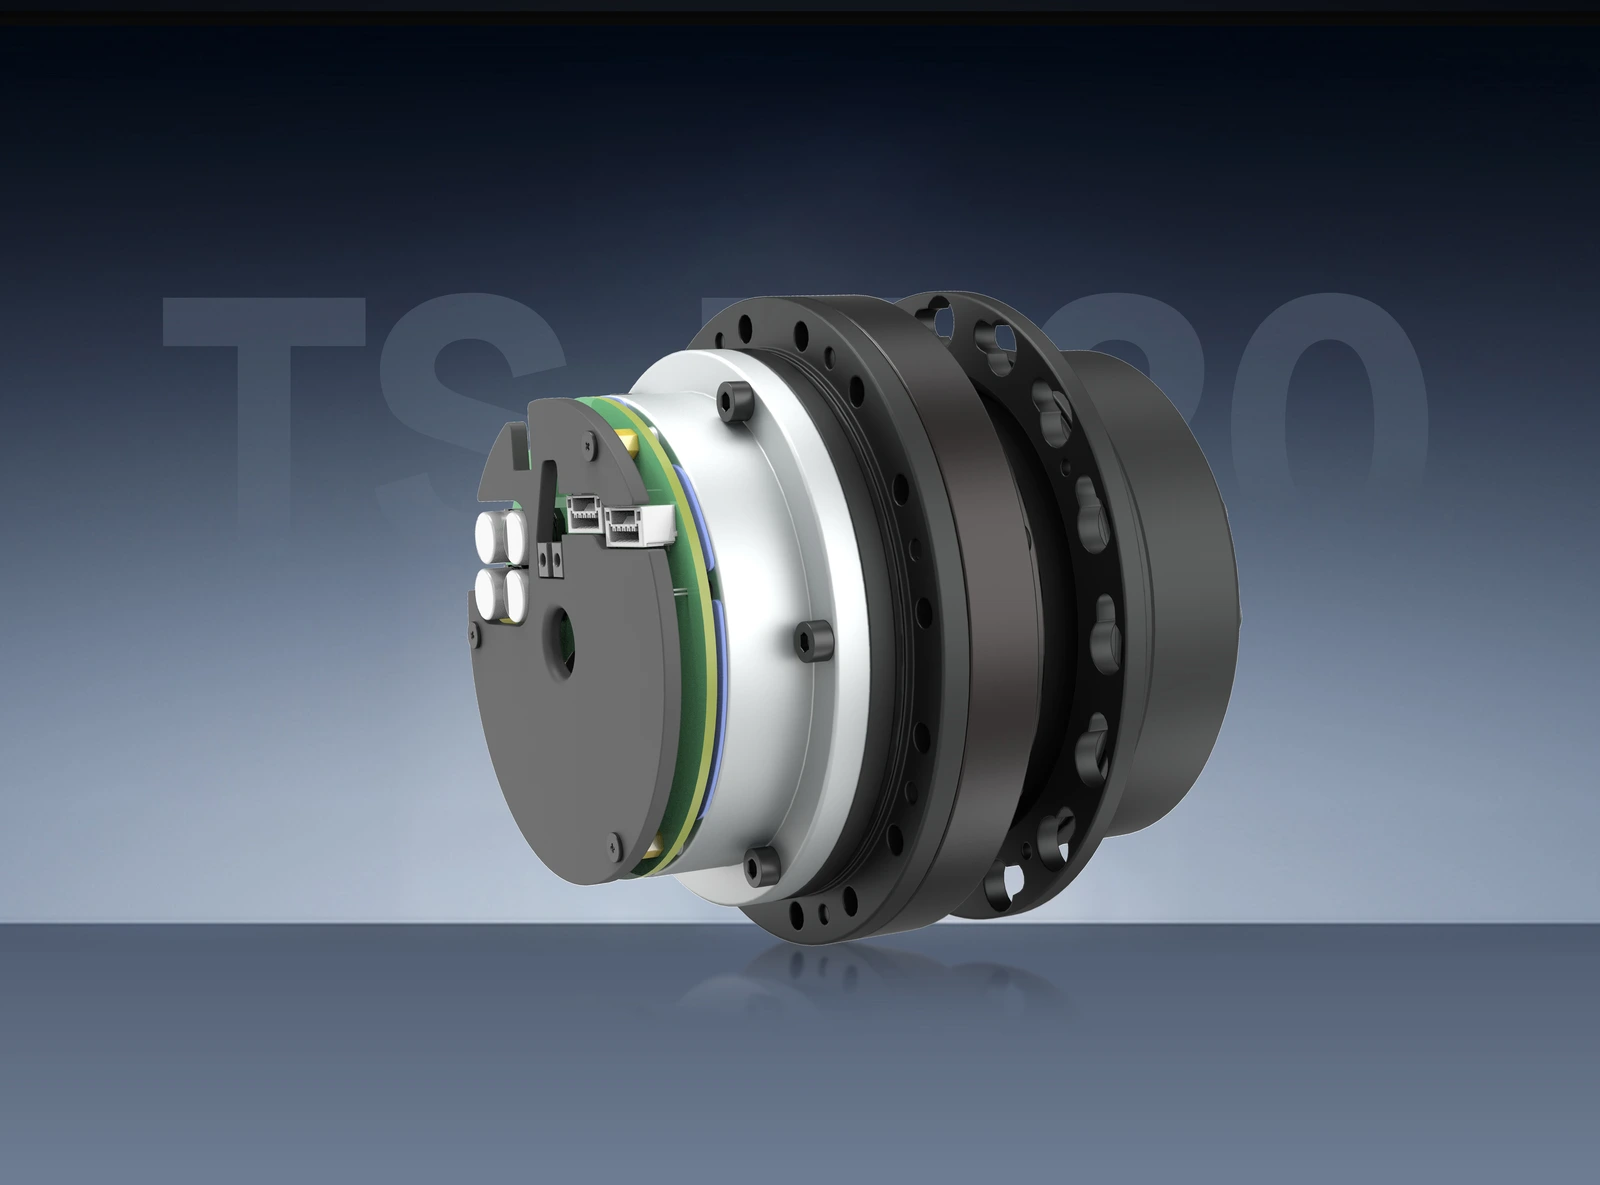
2026-11-16
Integrated rotary joint module series with 48 V supply, EtherCAT communication, 19-bit high- and low-speed encoders, electromagnetic braking and ratio-dependent torque and speed configurations.
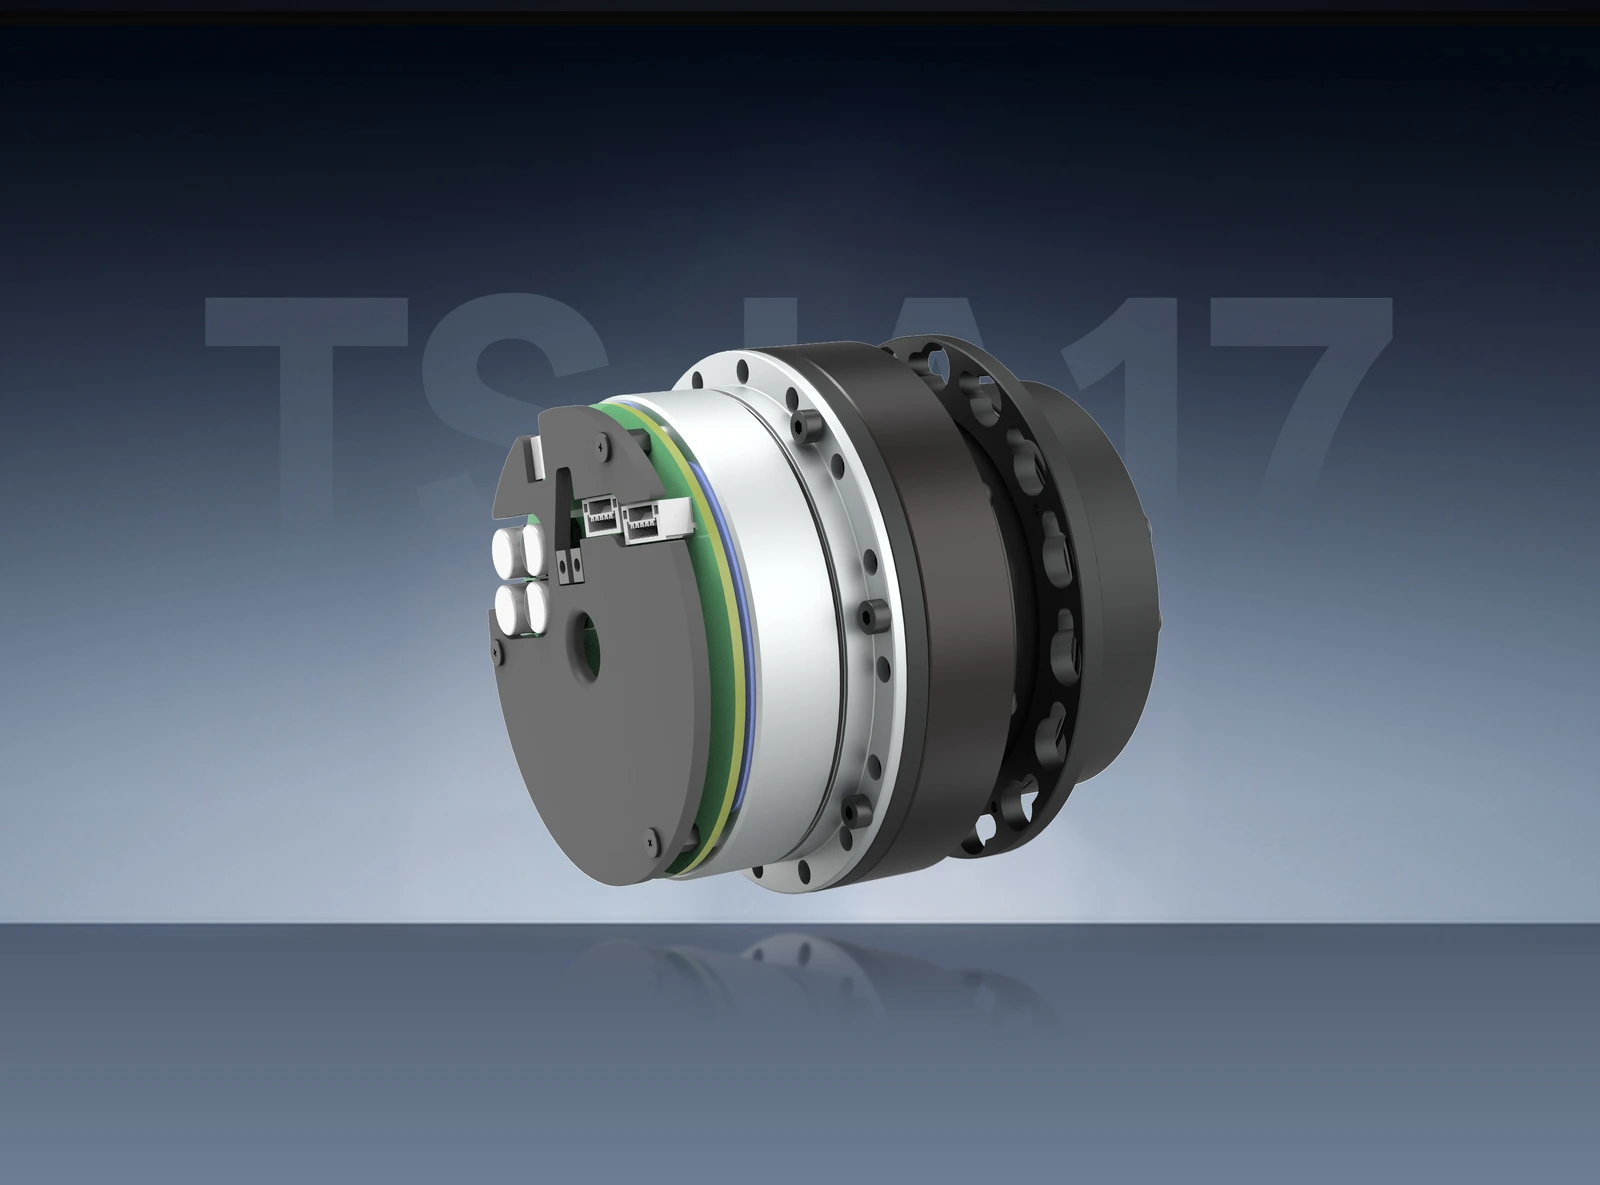
2026-11-16
Integrated rotary joint module series with 48 V supply, EtherCAT communication, 19-bit high- and low-speed encoders, electromagnetic braking and ratio-dependent torque and speed configurations.
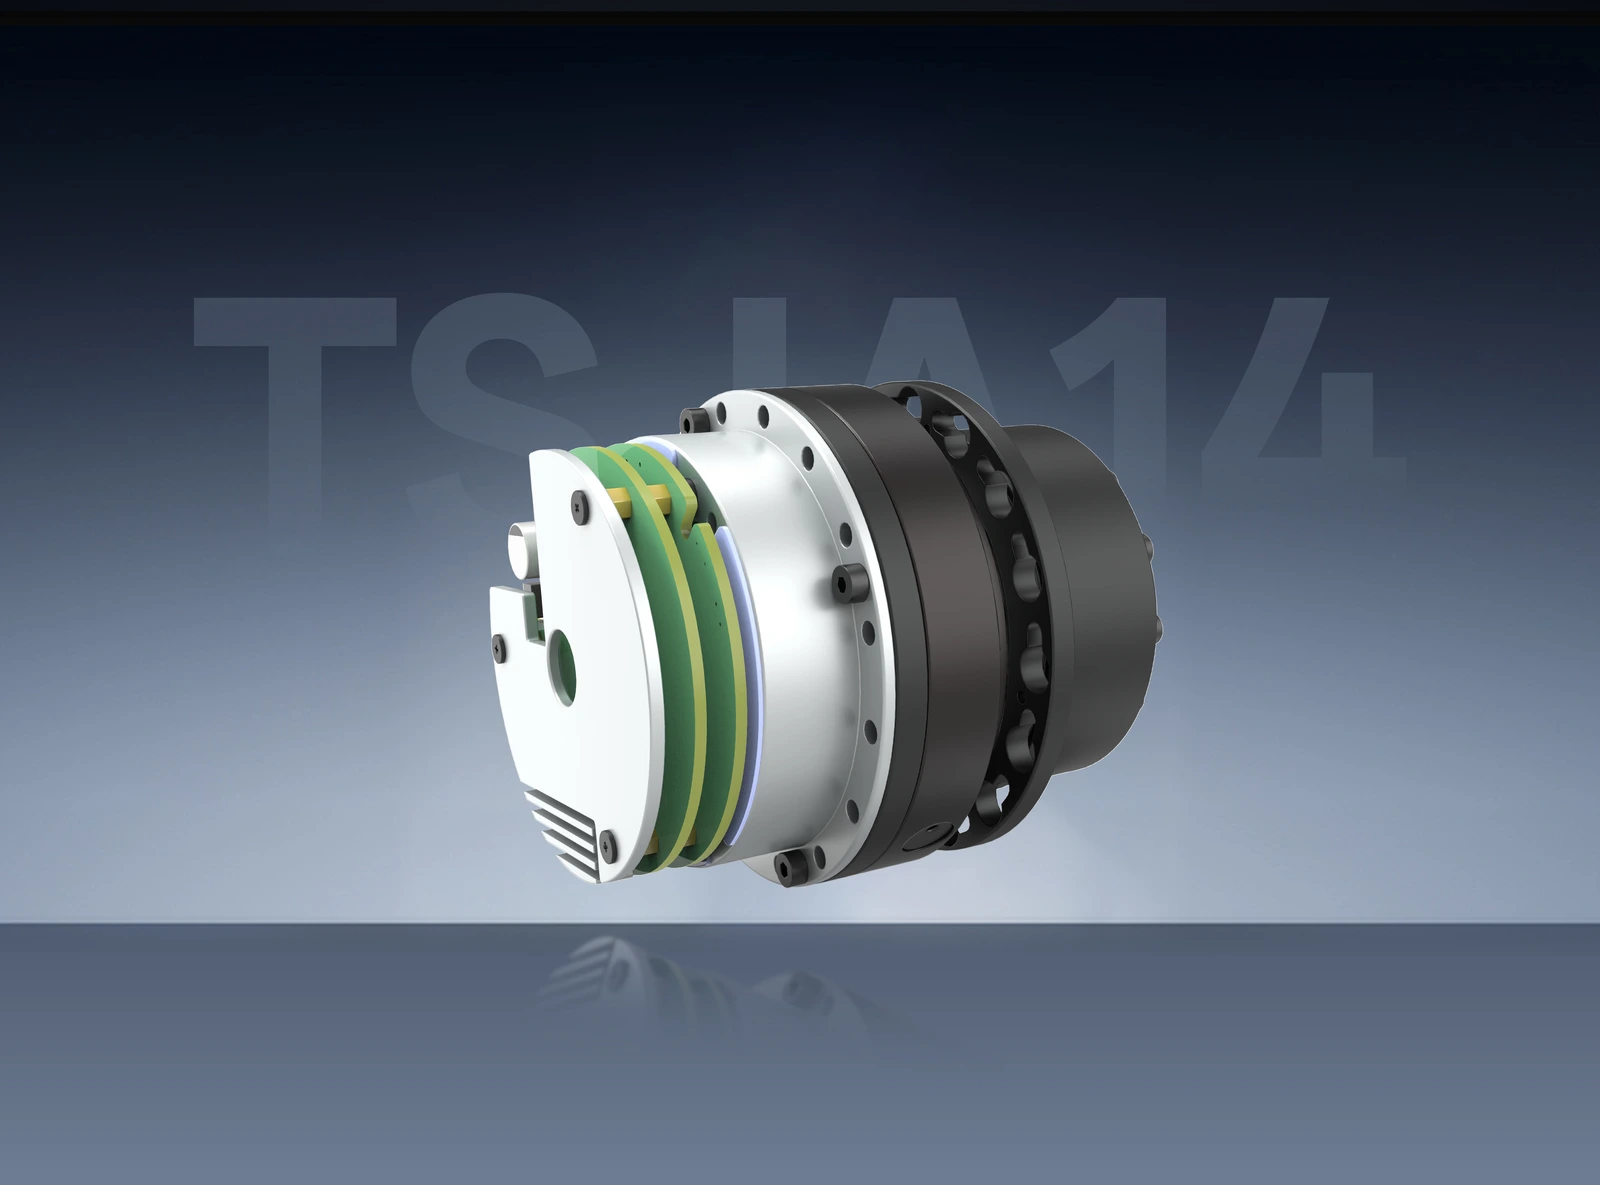
2026-11-16
Integrated rotary joint module series with 48 V supply, EtherCAT communication, 19-bit high- and low-speed encoders, electromagnetic braking and ratio-dependent torque and speed configurations.
2026-11-16
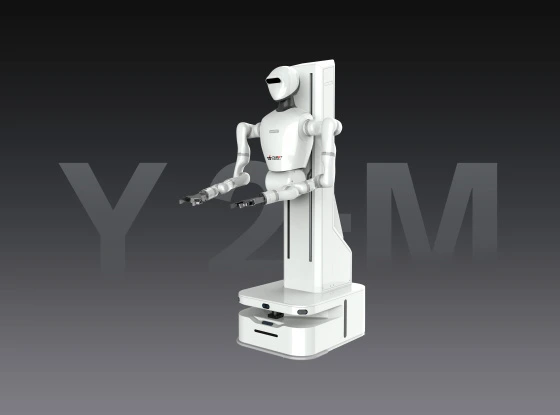
Mobile dual-arm lifting robot with a 700 mm lifting stroke, 5 kg rated load per arm, LiDAR autonomous navigation, laser obstacle avoidance, eight-hour working time and ROS2/API secondary-development support.